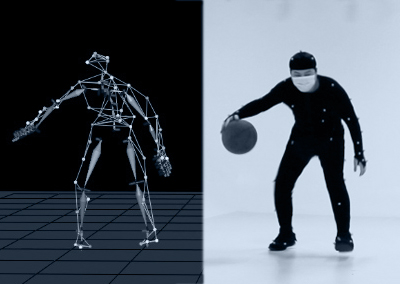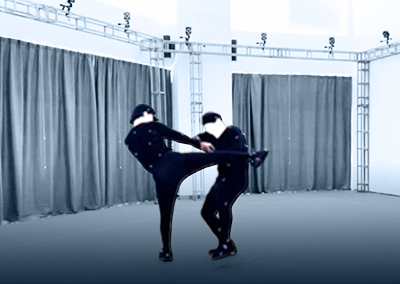
Real-time humanoid teleoperation requires three tightly connected stages: motion capture, motion retargeting, and robot control. Together, they form an end-to-end pipeline from human motion to robot execution.
The experimental platform shown in the video consists of three core components:
1. NOKOV Motion Capture System
Outputs real-time, submillimeter-level human motion data.
2. NKV-SE ReTarget (from ShadowEngine)
Performs dynamics-based motion retargeting from human motion to the target robot model, with batch simulation support.
3. NKV-SE TeleOp (from ShadowEngine)
Provides low-latency teleoperation powered by a general-purpose robot control model trained on 15,000+ motion samples, enabling stable and responsive robot execution.
ShadowEngine — an end-to-end platform for embodied AI and robot learning.


 Room820, China Minmetals Tower, Chaoyang Dist., Beijing
 info@nokov.cn
 + 86-10-64922321